Types of Industrial Robots and Their Uses in Modern Industries
Industrial robots have become an important part of modern manufacturing. They help businesses perform repetitive tasks, handle heavy materials, assemble products, and maintain consistent production quality. Different industries use different types of robots depending on the work involved, the available space, the required accuracy, and safety needs. Understanding these machines helps manufacturers choose suitable automation solutions for their operations.
From welding and painting to packaging and inspection, industrial robotics supports a wide range of production activities. Each robot type has its own design, movement pattern, and practical applications. This blog explains the main types of industrial robots, their uses across industries, the role of gripping systems, and the factors manufacturers should consider when selecting equipment for their production processes.
Understanding the Main Types of Industrial Robots Used in Manufacturing
Industrial robots are programmable machines designed to perform tasks with a high level of consistency. Their structure and movement determine which applications they can handle effectively.
Articulated Robots for Flexible Production Tasks
Articulated robots have multiple rotary joints that allow their arms to move in different directions. Their flexibility makes them suitable for welding, assembly, machine tending, and handling complex parts.
These robots are commonly used in automotive manufacturing, metalworking, and general assembly. Their ability to reach around obstacles makes them useful for tasks that require movement across several angles.
Cartesian Robots for Accurate Linear Movement
Cartesian robots move along straight lines using three perpendicular axes: X, Y, and Z. They are useful for applications requiring controlled positioning, such as dispensing, loading, unloading, and precision assembly.
Their straightforward movement system can make programming and maintenance easier. Manufacturers often choose them for operations that require repeatable movements within a defined working area.
SCARA Robots for Fast Assembly Operations
SCARA robots are designed for fast horizontal movements, with vertical movement available for positioning and assembly. They are commonly used to insert components, assemble small products, and transfer lightweight parts.
Their compact structure makes them suitable for electronics manufacturing and other production lines where speed and accurate positioning are important.
See also: Understanding the Process of Establishing an International Business
Delta Robots for High-Speed Sorting and Packaging
Delta robots use lightweight arms connected to a fixed base. They can move small objects quickly between positions, making them suitable for sorting, packaging, and food processing applications.
Their design supports rapid movements with low moving mass. However, their payload and working area must match the requirements of the production task.
Cylindrical Robots for Machine Loading and Handling
Cylindrical robots combine rotary movement with linear motion to operate within a roughly cylindrical workspace. They can be used for machine loading, material transfer, and selected assembly applications.
They are useful where tasks involve movement around a central axis and where the workspace does not require the flexibility of a multi-jointed robotic arm.
Collaborative Robots for Human-Shared Workspaces
Collaborative robots are designed to work alongside people in suitable applications. They can support assembly, inspection, packaging, and machine tending when an appropriate safety assessment is completed.
Their use does not automatically make an entire workstation safe. Risk assessments, suitable end effectors, operating limits, and safeguards must be considered before deployment.
How Industrial Robots Support Different Manufacturing Applications
The right robot depends on the production task, product characteristics, operating speed, and required level of precision. The following applications show how robots support everyday industrial processes.
Welding and Metal Fabrication
Robots can follow programmed paths to perform welding operations across repeated production cycles. They help maintain consistent torch movement, reduce operator exposure to heat and fumes, and support repeatable weld quality when properly programmed.
Assembly and Component Installation
Robots position parts, insert components, tighten fasteners, and perform other assembly steps. They are particularly useful when products contain many repeated components or require consistent positioning throughout a production shift.
Painting and Surface Treatment
Robotic systems can apply coatings along programmed paths, helping maintain consistent coverage and reducing direct worker exposure to paint and other potentially hazardous substances. Ventilation, coating control, and appropriate protective systems remain essential.
Inspection and Quality Control
Robots can move cameras, sensors, and measuring devices around a product to check dimensions, surface defects, or component placement. They can also position products for inspection, helping manufacturers identify defects earlier in the production process.
Improving Production Flow With Automated Picking and Material Movement
Moving products between workstations is a common manufacturing requirement. Automation can help reduce manual handling, improve workflow consistency, and keep production equipment supplied with materials.
Pick-and-Place Operations for Faster Product Transfer
Pick and place is a process in which a robot picks up an object from one location and places it at another. It is used in packaging, sorting, assembly, and component loading.
The robot’s gripper must match the object’s shape, weight, surface, and fragility. Vacuum gripping may suit flat surfaces, while mechanical grippers can hold objects by their sides or designated gripping points.
Robotic Material Handling Across Production Lines
Robotic material handling involves moving raw materials, components, workpieces, or finished products between different locations. Robots can load machines, transfer parts to conveyors, and move products into packaging stations.
These systems can reduce repetitive lifting and help maintain a steady supply of materials. Their effectiveness depends on correct payload selection, cycle time, layout planning, and coordination with other production equipment.
Using Manipulators for Controlled Object Movement
Manipulators are mechanical devices that help move, position, or control objects during industrial operations. Depending on their design, they may be manually operated, mechanically assisted, or integrated into automated systems.
They are useful when workers need better control over heavy or awkward objects, or when components must be positioned accurately during assembly and handling.
Why Gripping Technology Matters in Industrial Automation
A robot’s movement is only one part of the complete system. The equipment attached to its arm determines how it interacts with the workpiece.
Understanding EOAT and Its Role in Robot Performance
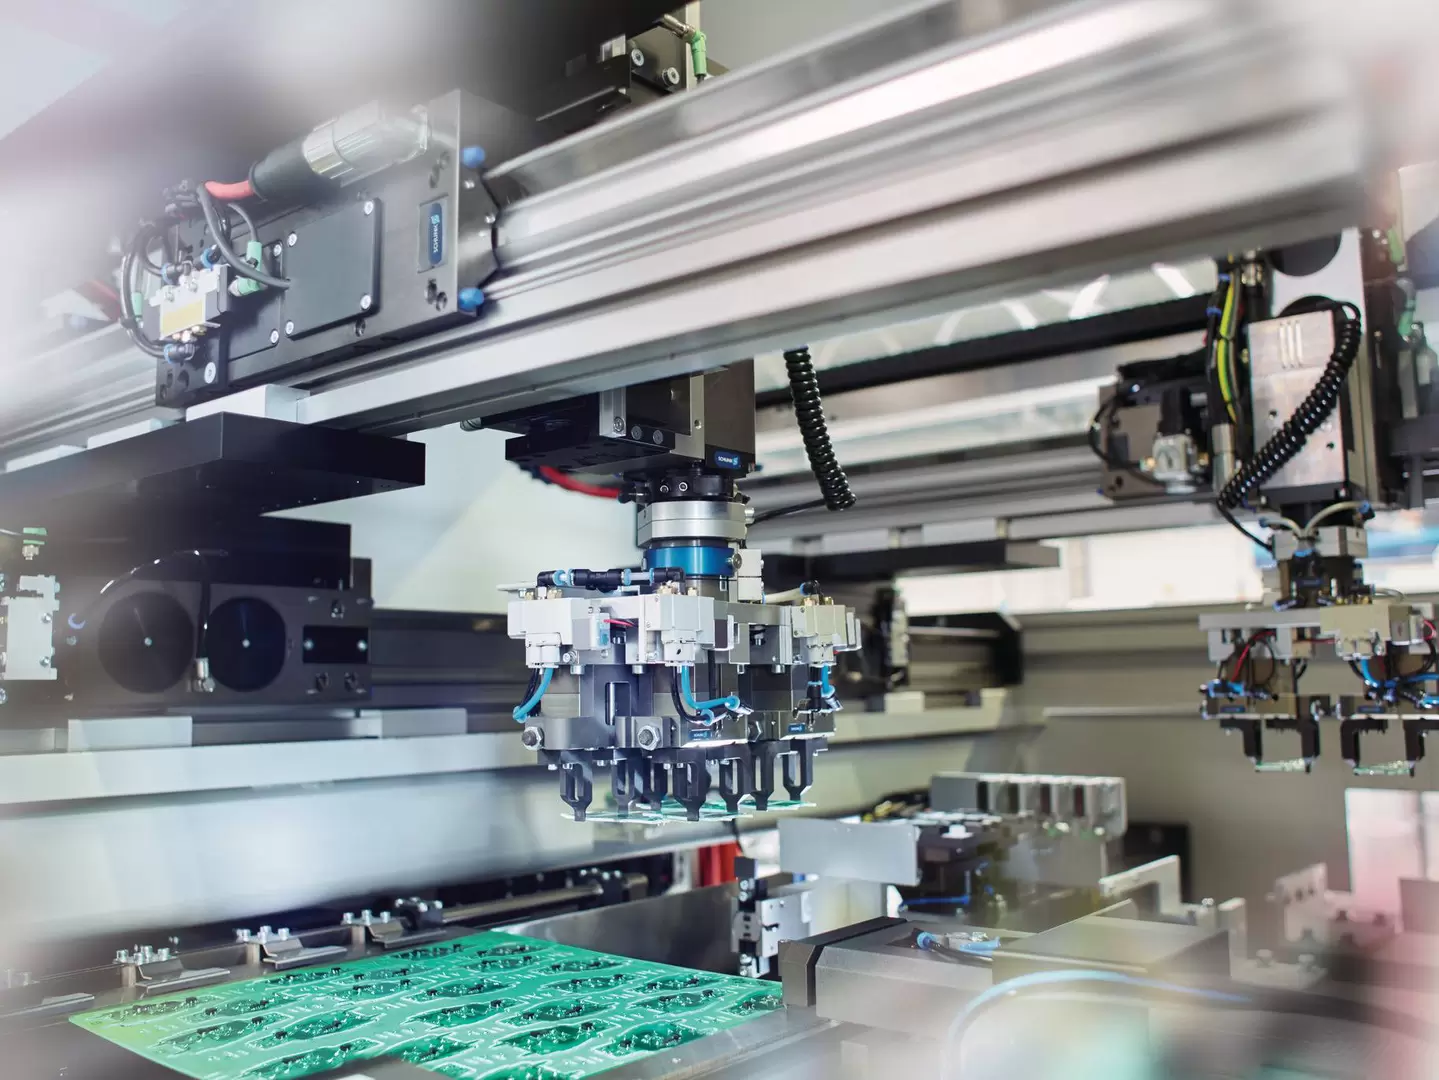
EOAT stands for end-of-arm tooling. It refers to the equipment fitted to a robot’s arm to perform a particular task, such as gripping, holding, cutting, welding, or inspecting an object.
The correct tooling helps a robot handle products reliably. Its design must account for payload, gripping force, object geometry, cycle speed, and the conditions in which the robot operates.
Choosing Suitable End-of-Arm Tooling for Each Task
End-of-arm tooling includes grippers, suction cups, welding tools, dispensing equipment, and other task-specific attachments. Each type is designed for a particular interaction with the workpiece.
For example, a delicate food item may require gentle gripping, while a metal component may need a firm mechanical hold. Selecting the wrong tooling can lead to product damage, dropped parts, or production delays.
Mechanical, Vacuum, and Magnetic Gripping Systems
Mechanical grippers hold objects using fingers or jaws. Vacuum systems use suction to lift suitable surfaces, while magnetic grippers handle compatible ferrous materials.
The choice depends on material type, surface condition, object weight, and environmental factors. Some applications require sensors to confirm that the object has been picked up securely before the robot continues.
Key Factors to Consider Before Selecting an Industrial Robot
Choosing a robot requires more than comparing its speed or purchase price. Manufacturers should evaluate the complete application, including tooling, installation, operating conditions, and long-term maintenance.
Payload and Reach Requirements
Payload refers to the weight a robot can safely carry, including its attached tooling and, where applicable, other supported equipment. Reach describes how far the robot can extend to access different work positions.
Speed, Accuracy, and Repeatability
Speed affects production output, while accuracy describes how closely a robot reaches a target position. Repeatability measures how consistently it returns to the same position under specified conditions.
The required performance depends on the task. Fast packaging may prioritize cycle time, while precision assembly may require tighter positioning control.
Safety, Integration, and Maintenance
Manufacturers must assess workplace hazards, emergency stops, guarding, sensors, and safe interaction between workers and machines. Integration with conveyors and production controls also matters.
Regular maintenance, staff training, spare parts planning, and access for repairs help maintain reliable operation over time.
How SCHUNK Contributes to Gripping and Automation Solutions
SCHUNK works across toolholding, workholding, gripping technology, and automation technology. Its expertise covers individual high-tech components as well as complete solutions for robot systems and different production processes.
Gripping technology is important in applications that require careful control over an object’s movement. For example, handling a delicate cookie without breaking it requires suitable gripping force, while processing very small micro-optical components requires precise control. Similarly, machining hip implant surfaces calls for appropriate workholding and tooling solutions.
These examples show why automation systems need to be designed around the actual task rather than relying on the robot alone. Grippers, fixtures, toolholders, and control systems must work together to support the required level of accuracy, product protection, and production consistency.
Conclusion
Different types of industrial robots serve different purposes in modern manufacturing. Articulated robots offer flexibility, Cartesian robots provide controlled linear movement, SCARA robots support fast assembly, and delta robots are suitable for high-speed sorting and packaging. Collaborative robots can assist with selected tasks alongside people when proper safety measures are in place. Choosing the right system requires careful consideration of payload, reach, speed, accuracy, workplace conditions, and maintenance needs.
Gripping technology and suitable tooling are equally important because they determine how effectively a robot handles each product. By matching equipment to actual production requirements, manufacturers can improve workflow consistency, reduce repetitive manual work, and support reliable operations. A well-planned automation system combines the robot, tooling, controls, and safety measures into one coordinated process.